معلومات أساسية
NVIDIA released NVIDIA Isaac ROS 5.0 at the ROSCon conference in Toronto, Canada, introducing new agentic workflows and platform support to help developers and AI agents build robots together. The free and open source collection of GPU-accelerated packages brings accelerated computing and physical AI models to the ROS community.
The release adds support for Ubuntu 24.04 and ROS Lyrical, providing a standard data-handling interface contributed through work with the Open Source Robotics Alliance. New Isaac skills for setup and manipulation offer reusable workflows, alongside agent-ready documentation and inference libraries like FoundationPose for object pose estimation and tracking up to 5.5x faster.
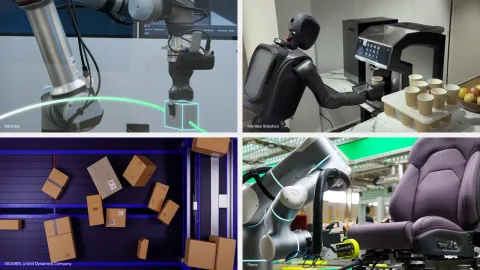
Ecosystem partners are actively adopting the tools. Ekumen utilizes Isaac ROS packages to enhance docking and obstacle detection, mapping collision-free arm paths on a GPU in roughly 2 to 5 milliseconds using isaac_ros_cumotion. Meanwhile, companies like Mentee Robotics and Universal Robots integrate the platform with NVIDIA Jetson hardware to run AI workloads at the edge.
Isaac ROS 5.0 supports scalable compute options ranging from the NVIDIA Jetson Orin Nano up to Jetson Thor devices. The software is available now for developers on GitHub.